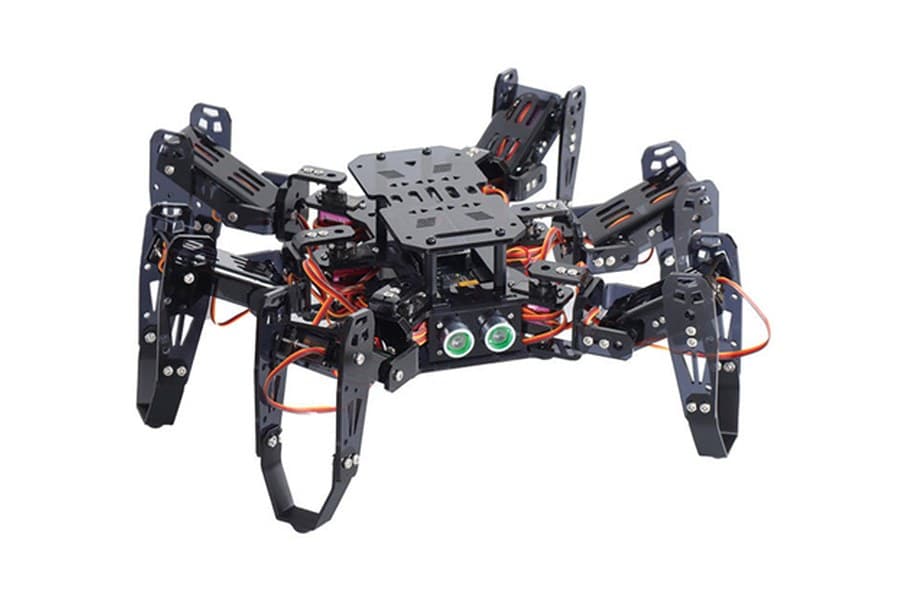
Spider Robot
A six-legged walker built one leg at a time. You start by testing a single leg, then coordinate all six into stable walking gaits — the same problem real legged robots solve, at desktop scale.
What you’ll learn
- Single-leg assembly and testing first
- Coordinating six legs into walking gaits
- Balance and stability across uneven ground
- Ultrasonic obstacle sensing
Class list
Work through these in order — finishing one unlocks the next. Complete them all and you earn 500 XP.
Class 1: Introduction to Spider Robots & ESP32 Architecture
Ready to start
Class 2: Parts of a Spider Robot
Locked — finish the previous class
Class 3: Electronics Basics (Power, Sensors & Controllers)
Power, signals, and the spark of electronics ⚡
Locked — finish the previous class
Class 4: Programming Basics (Teaching the Robot to Move)
Teaching your robot its first instructions
Locked — finish the previous class Code
Class 5: Servo Motors (The Muscles of the Spider Robot)
Locked — finish the previous class Code
Class 6: Robot Assembly (Building Your Spider Robot)
Locked — finish the previous class Code
Class 7: Degrees of Freedom (DOF) & Leg Kinematics
Counting the moves every joint can make
Locked — finish the previous class
Class 8: Single-Leg Testing & Movement
One leg at a time — first steps to walking 🦿
Locked — finish the previous class Code
Class 9: Multi-Leg Coordination
Getting every leg to work as a team
Locked — finish the previous class Code
Class 10: Walking Gaits (Tripod, Ripple & Wave Gaits)
Locked — finish the previous class Code
Class 11: Turning, Side-Stepping & Special Movements
Turns, side-steps, and moves with style
Locked — finish the previous class Code
Class 12: Wireless Control (Wi‑Fi & Bluetooth)
Cut the cord: control your spider robot wirelessly using the ESP32
Locked — finish the previous class Code
Class 13: Sensors, Obstacle Detection & Autonomous Navigation
Giving your robot eyes to sense the world
Locked — finish the previous class Code
Class 14: System Integration & Performance Optimization
Bringing every system together as one
Locked — finish the previous class Code
Class 15: Your Robotics Journey Begins (What You Can Build Next)
Locked — finish the previous class